

View All Events
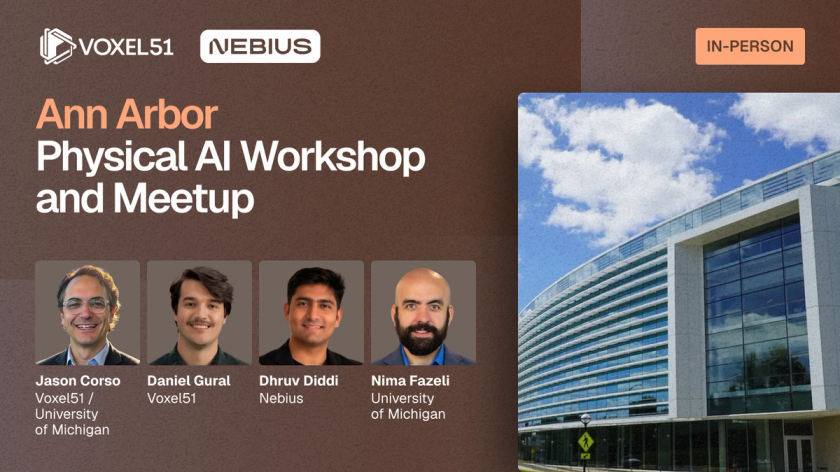
Ann Arbor Physical AI Workshop and Meetup - October 7, 2026
This event has ended, but you can still catch up! Watch the on-demand recordings and register for our future events.
Oct 07, 2026
6:00 PM - 10:00 PM EDT
Ford Motor Company Robotics Building (Room 1060), University of Michigan, Ann Arbor, MI
Speakers
About this event
Join us in Ann Arbor on October 7th for the Ann Arbor Physical AI Workshop and Meetup, co-presented by Nebius and Voxel51.
The evening opens with lightning talks from Nima Fazeli and Jason Corso, followed by a food break and a hands-on workshop on building physical AI applications with FiftyOne, from curating robotics and sensor datasets to evaluating vision models on real-world data. Networking continues after the workshop.
A laptop is required to participate in the hands-on workshop - please bring one. Space is limited, so register early.
A company, university, or government email address is required to take part in the hands-on workshop. Personal and disposable email accounts (Gmail, Yahoo, Outlook, and similar) cannot be used for the workshop environment. This is a blanket policy of the workshop platform to prevent fraud and abuse and to meet compliance requirements. If you need an exception, contact the hosts before the event.
Schedule
Hosts
Vision-based Tactile Sensing -- Turning Touch to Images
Tactile sensing is critical to a robot's dexterous manipulation capabilities. It informs the robot of what it is touching, and how hard it is touching. In recent years, inspired by rapid progress in computer vision, researchers have developed tactile sensors that are tiny cameras at the fingertips. In this talk, we will review these sensors and the capabilities they unlock for robotics.
Resources
Lightning Talk
Agenda
6:00 PM
- Welcome and intro from Dan Gural
6:05 to 6:20 PM
- Lightning talk: Nima Fazeli
6:20 to 6:35 PM
- Lightning talk: Jason Corso
6:35 to 7:00 PM
- Food break
7:00 to 8:30 PM
- Workshop
8:30 to 10:00 PM
- Networking and close
Workshop Agenda
This hands-on session uses DROID, a real-world robotics dataset loaded into FiftyOne as a native multimodal MCAP recording, and YOLO11n, fine-tuned live during the session.
- Welcome + framing: from raw robot logs to a trained detector
- Explore a real DROID robotics recording in FiftyOne's native multimodal MCAP viewer: camera, proprioception, and language on one synced timeline, no ROS install required
- Curate: extract and browse frames from the recording, filter and deduplicate
- Compute embeddings on the curated frames; explore via similarity search and embeddings visualization (via Nebius Serverless AI Jobs)
- Auto-label: open-vocabulary detection to generate bounding boxes for the robot gripper and target objects
- Train: fine-tune a YOLO11n detector on the auto-labeled frames (via Nebius Serverless AI Jobs)
- Evaluate results and close the loop: view predictions back on the original MCAP timeline
- What else Nebius offers: Token Factory walkthrough — chat/vision models, fine-tuning, credits
© 2026 Voxel51 All Rights Reserved