End-effector
An end-effector, also written end effector and often abbreviated EE, is the device at the end of a robot arm that interacts with the world, such as a gripper, hand, suction cup, or specialized tool. It is the part that actually does the work, so its pose and state are often what a control policy is ultimately trying to control. Everything else the arm does exists to place and orient the end-effector where it needs to be.
In this article
Building visual or physical AI?
Let's talk.
What is an end-effector?
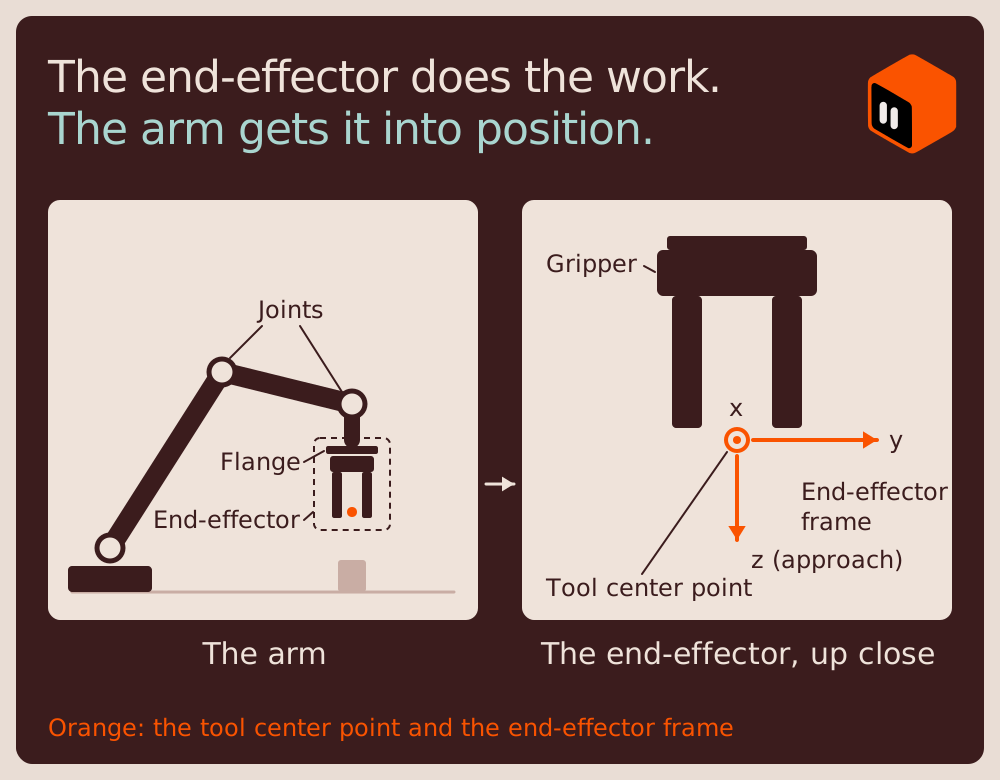
An end-effector is the working end of a robot arm, the part that actually touches and manipulates the world. Depending on the job, it might be a simple two-fingered gripper, a dexterous multi-fingered hand, a suction cup, or a specialized tool like a welding torch or a screwdriver. Whatever its form, the end-effector is where the robot's intentions meet reality. The rest of the arm exists largely to carry the end-effector to the right place and hold it at the right angle so it can do its job.
Because the end-effector is what interacts with objects, its position, orientation, and state are usually the things a control policy cares about most. When a robot is told to pick up a cup, what matters is getting the gripper to the cup, oriented correctly, and closing it at the right moment. For this reason, actions are often expressed in terms of the end-effector, describing where it should go and what it should do, rather than in terms of every individual joint. Its state, such as whether a gripper is open or closed, is also a key part of the robot's proprioceptive self-sensing.
Industrial robotics uses a few related terms for the same idea. End-of-arm tooling, or EOAT, is the common manufacturing term for the end-effector. The tool center point (TCP) is the specific point on the end-effector, such as the midpoint between gripper fingertips or the tip of a welding torch, that the robot positions when it moves. The end-effector frame is the coordinate system usually attached at that point, and an end-effector pose is that frame's position and orientation in space.
Key takeaways
- An end-effector is the device at the end of a robot arm that interacts with the world, such as a gripper, hand, or tool.
- Its pose and state are often what a control policy is ultimately trying to control.
- Actions are often expressed in terms of the end-effector rather than every individual joint.
- Robot learning datasets record end-effector pose and gripper state, and policies can act in joint space or end-effector space.
Types of end-effectors
End-effectors are usually grouped by how they make contact with objects. In robot learning, the type also shapes how the end-effector shows up in the data.
| Type | How it works | How it appears in robot learning data |
|---|---|---|
| Parallel-jaw gripper | Two fingers close toward each other to pinch an object | Usually one action dimension for how open or closed the gripper is |
| Dexterous hand | Several jointed fingers, sometimes with tactile sensing | Many action dimensions, often one per finger joint, which makes demonstrations harder to collect and policies harder to train |
| Suction or vacuum gripper | Negative pressure holds an object by a smooth or flat surface | Often a single on or off action |
| Specialized tool | A fixed tool such as a welding torch, screwdriver, or spray nozzle | A tool on or off signal, or no extra dimension for a passive tool, so the task depends mostly on the tool's pose |
How it works
A robot arm's joints work together to position and orient the end-effector, so controlling the arm is often framed as deciding where the end-effector should be and letting the joint motions follow from that. The end-effector's pose is its position and orientation in space, and its state captures what it is doing, such as how far a gripper is open. A control policy frequently outputs targets for the end-effector, and the system then figures out the joint movements needed to achieve them. Proprioceptive sensing reports the end-effector's current pose and state so the controller always knows where the working point of the robot is.
End-effectors in robot learning data
Robot learning datasets record what the robot sensed and what it was commanded to do, and the end-effector appears in both. There are two common ways to represent an arm's actions. Joint-space actions give a target for every joint. End-effector-space actions, sometimes called Cartesian actions, give a target pose for the end-effector, usually a 3D position plus an orientation, and leave inverse kinematics to work out the joint angles. Both usually add one or more dimensions for the gripper.
Datasets and policies make different choices. The SO-101, the arm behind many LeRobot community datasets, stores the positions of its six motors, five arm joints plus the gripper, as both its state and its action. Only the gripper value describes the end-effector directly. DROID stores the end-effector's Cartesian pose, the gripper position, and the arm's joint positions side by side, so each training pipeline can choose which action space to learn from. The Universal Manipulation Interface (UMI) expresses actions as end-effector trajectories relative to the gripper's current pose, and its authors deployed the resulting policies on both UR5e and Franka arms fitted with a matching parallel-jaw gripper.
Because end-effector trajectories capture what a demonstration actually did, they are also a practical place to check data quality. Jittery end-effector motion, a gripper that closes before the camera shows contact, or leader and follower arms that disagree about the gripper's position are all signs that a demonstration needs review before training. Voxel51 loads LeRobot datasets and plays back camera streams in sync with joint state and actions, so you can see what the gripper was commanded to do at the moment a grasp fails.
Why it matters
The end-effector matters because it is where a robot's work actually gets done, which makes it the natural focus for both control and evaluation. For anyone reasoning about manipulation, thinking in terms of the end-effector clarifies what a task really requires, since most manipulation goals are ultimately statements about where the gripper or tool needs to be and what it needs to do. Understanding this helps explain why so much of robot control and robot data is organized around the end-effector rather than around individual joints. It also makes the end-effector a practical lens on data quality, since problems in a demonstration often show up in what the gripper or tool did.
Frequently asked questions
Why are actions often specified for the end-effector rather than each joint?
Because most tasks are really about what the working point of the robot does, such as reaching and grasping an object. Specifying the end-effector's target pose captures the goal directly, and the system can then work out the joint motions needed to achieve it.
What is the difference between an end-effector's pose and its state?
Its pose is its position and orientation in space, describing where it is and which way it faces. Its state describes what it is doing, such as whether a gripper is open or closed. Both are important for control.
Is a robot hand an end-effector?
Yes. A gripper, a dexterous multi-fingered hand, a suction cup, or a specialized tool all count as end-effectors. The term covers whatever device sits at the end of the arm and interacts with the world. Wheels are not called end-effectors. In legged robot research, feet are sometimes treated as end-effectors because they are where the limb contacts the world.
What is the most common type of end-effector?
In robot learning, the most common end-effector is a two-finger gripper. DROID, UMI, and the SO-101 all use one, since a single open or close dimension keeps demonstrations and policies simpler than a multi-fingered hand. Industrial robots also use suction grippers and specialized tools such as welding torches.
What is the difference between an end-effector and an actuator?
An actuator is a component that produces motion, such as the motor that turns a joint. An end-effector is the device at the end of the arm that interacts with objects. Many end-effectors contain their own actuators, such as the motor or air cylinder that closes a gripper, but the two terms describe different things.
Is an end-effector the same as end-of-arm tooling (EOAT)?
Yes, in practice. End-of-arm tooling is the term manufacturers and integrators usually use, while robotics research and robot learning more often say end-effector. Both refer to the gripper, hand, or tool mounted at the end of the arm.
Related terms
Director of Growth
Jesse Mostipak is the Director of Growth at Voxel51, where the work is helping humans find and trust what the brand knows, and teaching the Google knowledge graph and the LLMs answering on their behalf to do the same. That question, how knowledge gets built inside a system, is one Jesse has been chasing for years. Earlier versions of it ran through a New York City high school science classroom, data science and machine learning, and developer relations at Kaggle, Posit (formerly RStudio), and Baseten. The answer doesn't change much depending on whether the learner is a teenager, a software engineer, or a knowledge graph. Jesse holds a Master's in Education from CUNY Hunter College. LinkedIn
See all articles by Jesse Mostipak
Last updated November 11, 2026
Building visual or physical AI?
Let's talk.
© 2026 Voxel51 All Rights Reserved